This research area aims to develop validated artificial structures such as bones and soft tissue. They are the main components of the patient phantom and essential for imitating realistic haptic feedback.
Artificial bones
Orthopaedic interventions require cutting, drilling or penetrating bone. Artificial bones incorporated into the patient phantom should therefore imitate human bone as closely as possible in order to achieve realistic haptic feedback. Depending on the intervention, this haptic feedback is characterised, for example, by
- the needle insertion force during penetration of the vertebra in cement augmentation techniques (see Figures 1 and 2),
- the torque when inserting a screw for osteosynthesis, or
- the cutting forces when sawing, drilling or milling bone tissue during orthopaedic surgery.
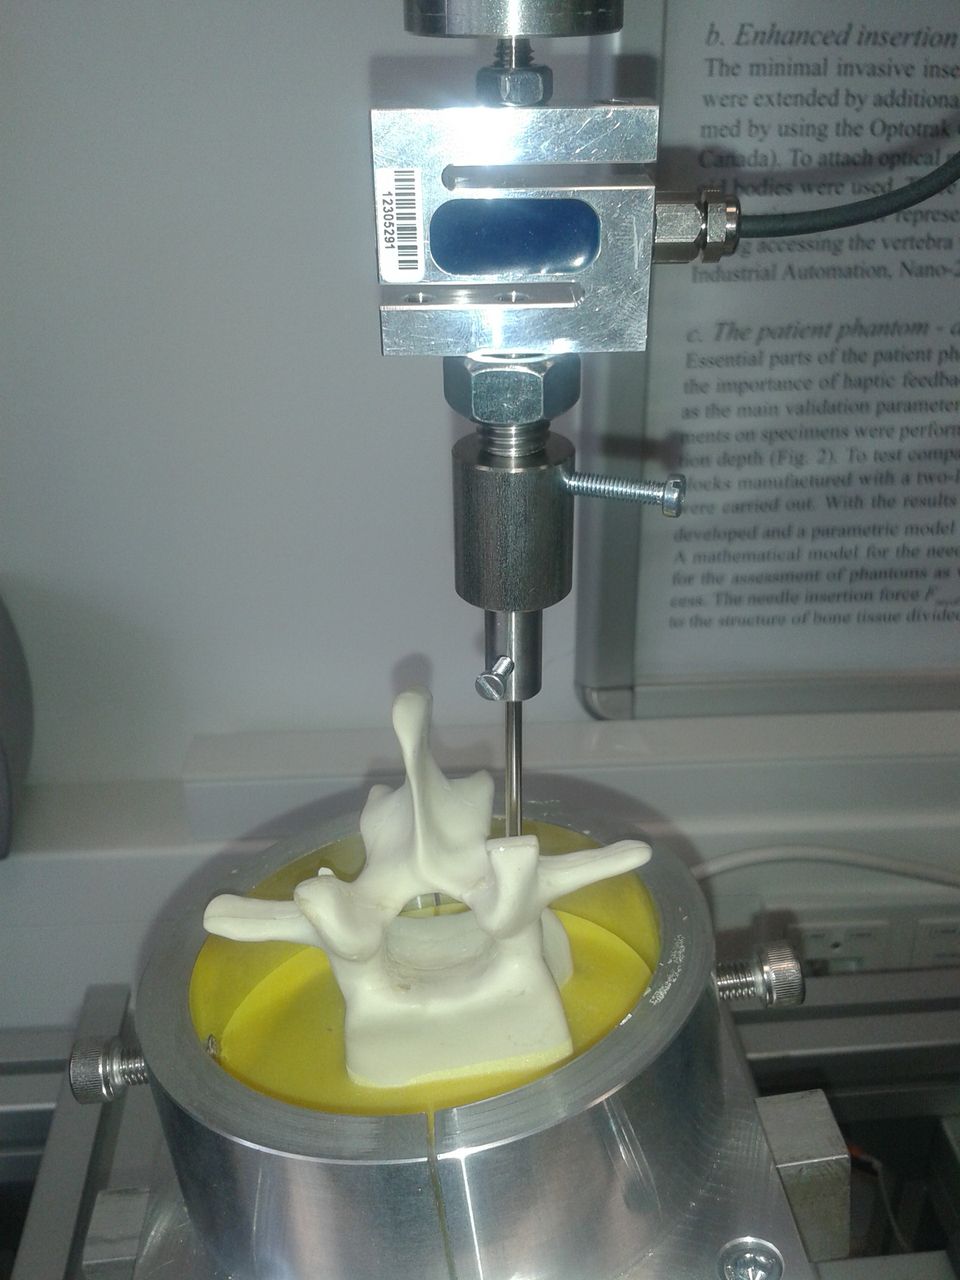
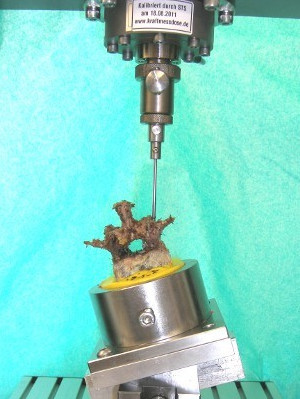
Developing artificial bone structures involves various rapid prototyping technologies, including 3D printing and moulding, with different materials for imitating cortical and trabecular bone. Since these two bone tissues differ in both mechanical properties and morphology, materials with very different processing properties have to be combined. For the artificial vertebrae used in a cement augmentation simulator, the trabecular bone is imitated by a polyurethane (PU) foam. The PU foam is cast into resin shells of different material properties and thicknesses and shows realistic needle insertion forces compared with human specimens [1], [2].
Current research focuses on improving the trabecular structure to allow balloon dilatation and cement injection, and on improving the cortical layer to allow screw insertion, cutting and milling.
Artificial soft tissue
Artificial muscles and connective tissue can be made of silicone, with silicone rubber as the base material. Silicone oil is added to the rubber in different proportions of the total mass to achieve more realistic viscoelastic behaviour and to provide a kind of lubrication when the needle penetrates the tissue. Layered artificial structures are created by stacking discrete silicone layers with distinct ratios of silicone rubber to silicone oil.

To validate the artificial tissue blocks, biomechanical measurements are performed on human tissue specimens and compared with the artificial samples. In cement augmentation, the needle penetrates the soft tissue, so the needle insertion force serves as the characteristic parameter. Since human soft tissue shows distinct viscoelastic behaviour, the measurements are performed in three phases (see Figure 3): insertion – relaxation – extraction.
- Insertion: the needle is inserted into the specimen to a predefined depth at a predefined feed rate.
- Relaxation: the needle is held still for a defined period of time.
- Extraction: the needle is withdrawn at a predefined feed rate.
As shown in [3], an artificial tissue block made of silicone imitates human muscle tissue with tendon and skin quite well.
Future research will address layered structures, structures with incorporated fibres, and artificial intervertebral discs.
References
- (2012): Foam phantom development for artificial vertebrae used for surgical training.. In: Conf Proc IEEE Eng Med Biol Soc, vol. 2012, pp. 5773–5776, 2012.
- (2013): Artificial Vertebrae for a Novel Simulator in Minimally Invasive Spine Surgery.. In: Biomed Tech (Berl), 2013.
- (2014): Artificial muscles for a novel simulator in minimally invasive spine surgery.. In: Conf Proc IEEE Eng Med Biol Soc, pp. 506-509, 2014.